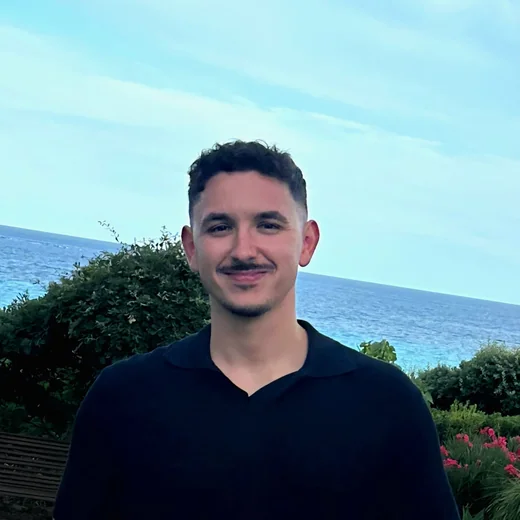
Alejandro Sanchez Ferrer
Senior AI Solutions Architect & PhD Researcher
Building production-ready computer vision systems from edge devices to the cloud
About Me
Senior AI Solutions Architect and PhD researcher with 5+ years delivering Computer Vision and Deep Learning solutions for urban infrastructure, public transport, traffic management, and environmental safety.
Hands-on expertise across the full AI lifecycle — from VLM fine-tuning (SFT, LoRA, QLoRA) and production optimization (TensorRT, Triton) to edge, cloud, and on-prem deployments. Proven track record building AI-powered solutions at city and regional scale across Spain, Europe, and the United States.
Customer-facing technical expert, effective in partnering with Sales, Product, and Engineering stakeholders to translate mission goals into successful AI-enabled deliveries. Adjunct Professor of AI and active technical contributor through publications, open-source projects, and community engagement.
Experience
Minsait (Indra Group)
Senior AI Solutions Architect & Technical LeadMadrid / Alicante, Spain
- Defined technical roadmap and methodology for up to 5 engineering teams (Backend, Data, Deployment), establishing best practices for development and testing.
- Led design and deployment of 10+ Computer Vision products across urban, transport, aviation, energy, and environmental sectors in Spain, Europe, and the US.
- Architected scalable, low-latency pipelines for 24/7 vision inference; reduced inference latency by over 80% (from +1s to sub-200ms).
- Led technical engagement with enterprise clients, building PoCs, demos, and advising on successful solution delivery.
IFFE Business School
Adjunct Professor (Master in AI)A Coruña, Spain
- Instructed graduate-level course on "Principles of Robotic Autonomy," covering perception, navigation, computer vision, and multimodal AI.
- Developed and delivered technical presentations and educational materials on complex AI topics.
uWare Robotics
Robotics Engineer (Intern)Alicante, Spain
- Developed and optimized real-time control modules in Python and ROS for autonomous underwater vehicles (AUVs).
Embention
Software Verification Engineer (Intern)Alicante, Spain
- Implemented and verified safety-critical drone flight control algorithms in C/C++14/17 on a real-time Linux-based embedded system.
Projects
SESAR NEURON | Next-Gen Airport AI
Solution design and kick-off lead for AI visual intelligence in digital towers within NEURON, the SESAR 3 JU project coordinated by Indra. Ongoing (2026-2029).
NEURON (NEw aiRport Operational service Network) is a SESAR 3 Joint Undertaking project under Horizon Europe, coordinated by Indra with EUROCONTROL as network integrator and a 23-partner consortium including Airbus, ENAV/TechnoSky and early-adopter airports such as Athens International Airport. I designed the end-to-end technical solution and led the kick-off of the AI-enabled visual intelligence solution for digital towers: real-time visual tracking, trajectory smoothing, video-based weather detection and aerodrome safety monitoring, targeting TRL6. The project is ongoing, running from 2026 to 2029 towards SESAR's Digital European Sky vision.
Q-SPAM | Quadruped Surveillance Platform
Quadruped robot with AI for real-time detection, tracking, pose estimation and multimodal reasoning.
This project, created in partnership with Minsait, integrates a quantized VLM into a quadruped robot for real-time query-based reasoning, tracking, and behavior recognition, demonstrating Physical AI in edge-constrained environments. The robot is equipped with a high-resolution camera enabling seamless detection, tracking, pose estimation, and behavior analysis of individuals.


WindEye | Vision Integrated Radar Detection
Multi-sensor bird detection in wind farms integrating vision and radar. 8+ wind farms deployed.
Multi-sensor detection system integrating vision and radar to classify endangered bird species and trigger automatic turbine shutdown. Deployed in 8+ wind farms across Spain, supporting environmental regulation compliance. Utilizes 3D radar technologies and high-resolution video capture to detect and classify birds in real time.

GridEye | Smart Wildfire Detection
Solar-powered early wildfire detection with Transformers on Jetson Nano/Orin. 20+ devices deployed.
Compact, solar-powered early wildfire detection system using Transformer models optimized with TensorRT for Jetson Nano/Orin Nano. Deployed in 20+ devices across Spain for public safety and environmental protection. Winner of the Enertic Award for predictive maintenance innovation.
BESOS | Smart Emissions Monitoring
Real-time emissions monitoring for power plants using Computer Vision and IoT.
Intelligent surveillance platform for Endesa/Enel, monitoring power plant emissions with advanced Computer Vision algorithms detecting anomalies such as smoke, foam, debris, and thermal irregularities. Critical for maintaining ecological balance and ensuring regulatory compliance in energy production facilities.
SEAT | Automated Quality Assurance
Computer vision inspection for electric track systems in vehicle assembly lines.
Developed for SEAT, this project applies computer vision to enhance reliability of electric track systems in vehicle assembly lines. Advanced image processing algorithms provide real-time surveillance over transport rails, proactively identifying defects and deviations from standards.
Mobeye | Metro Access Control
Real-time person tracking and tailgating detection embedded in metro access gates.
Real-time person tracking and tailgating detection system embedded in metro access gates for a major transport operator, enhancing public transport safety and access control. Uses computer vision to detect unauthorized entries and ensure passenger flow management.
Traffic Control Copilot | Sign Compliance AI
AI-powered traffic sign detection and compliance verification on Azure. Deployed in Texas, USA.
AI-powered traffic sign detection, tracking, classification, and automated compliance verification against construction blueprints. Deployed on Azure cloud with Computer Vision and Generative AI for a leading infrastructure company in Texas, USA.
FishEye | Retail Analytics
Real-time person monitoring with ceiling-mounted fisheye cameras for telecom retail.
Real-time person monitoring using ceiling-mounted fisheye cameras for a major telecom retailer, extracting operational KPIs (foot traffic, wait times, heatmaps) to improve service delivery and citizen experience. Provides actionable insights for store optimization.
Multi-Object Tracking | Telecom POC
Real-time multi-object tracking proof of concept for a major telecom operator.
Proof of concept for a major telecommunications operator: real-time multi-object detection and tracking over live camera feeds, with identity persistence across occlusions and camera handoffs. The pipeline combines state-of-the-art detectors with modern tracking-by-detection algorithms, optimized for GPU inference and designed to scale across large camera networks.
OceanGuard AI | On-Device Marine Debris Detection
Fully offline Android app detecting marine debris on-device with Gemma 4 Vision and RT-DETRv2.
Born as an AI platform for mapping marine pollution with a fine-tuned Gemma3n VLM (Google Gemma3n Hackathon), and evolved for the Gemma 4 Good Hackathon into a fully offline Android app that runs two AI models entirely on-device: RT-DETRv2 for real-time camera scanning (~30ms per frame) and Gemma 4 E2B Vision as a zero-shot visual detector generating native bounding boxes. The app also produces on-device environmental impact reports, plots GPS-tagged detections on offline maps, gamifies cleanups with a MarineDex field guide and ships in 6 languages, with zero cloud dependency.

PadelCortex | Smart Tournament Scheduling
Padel tournament organizer with automatic scheduling from player and club availability.
Full-stack web platform that organizes padel tournaments end to end: it collects each pair's availability, crosses it with the club's court schedule and generates (or reorganizes) the brackets while minimizing player displacements. Built with Next.js and React, TypeScript, Tailwind CSS and Prisma over PostgreSQL, with bilingual UI and a decoupled scheduling engine combining greedy heuristics with local search.
Myoelectric Mobile Robot Control
Robot control using myoelectric signals with dynamic obstacle avoidance and person tracking.
Control system for a mobile robot combining myoelectric control with proximity sensors for obstacle avoidance and active tracking of people in real time. A robust algorithm was implemented to ensure safe navigation in dynamic environments.
UI Design for Collaborative UR3 Robot
Intuitive interface for comprehensive control of a collaborative UR3 robot.
Designed an intuitive and functional UI for comprehensive control of a collaborative UR3 robot. The interface allows real-time monitoring and execution of various functions, facilitating seamless interaction between operator and robot.
Real-Time Chess with IRB120 and AI
AI-powered chess system with an IRB120 industrial robot playing in real time.
System where an IRB120 robot, assisted by AI algorithms, plays chess in real time. It can control both sides or enable remote play, offering an interactive and challenging experience in human-robot interaction.
Multi-Robot Bomb Extraction Simulation
Collaborative multi-robot strategies for bomb extraction and safe transportation.
Multi-robot system simulating collaborative strategies for bomb extraction and safe transportation. Coordination and simulation algorithms replicate team behavior in high-risk scenarios.
Intelligent Warehouse System Simulation
Multi-robot product collection system for intelligent warehouse logistics.
System of collaborative robots for collecting and transporting products within an intelligent warehouse. Optimizes internal logistics and improves operational efficiency through real-time planning and control algorithms.
Multi-Robot Line Following System
Coordinated multi-robot line-following on a circuit track.
Multiple robots coordinating to perform a line-following task on a circuit. Collaborative control and communication algorithms ensure precise and coordinated execution.
Candy Crush Bot | Classical Vision
Automated gameplay bot using classical computer vision algorithms.
Bot that uses classical computer vision methods to interpret game state and make real-time decisions for playing Candy Crush. Automates gameplay providing an innovative solution in game automation.
Live Demos
Real-time Computer Vision models running entirely in your browser — no server required
Skills
Multimodal AI
Deep Learning Frameworks
Model Tuning & Optimization
System Integration
Cloud & MLOps
Deployment
Languages
Education
PhD in Computer Vision
University of Alicante -PRAIG Group
2023 -PresentResearch on synthetic data generation and diffusion models for robust vision systems in complex underwater environments.
MSc in Automation & Robotics
University of Alicante
2022 – 2023 Honors — Best Final ProjectBSc in Robotic Engineering
University of Alicante
2016 – 2021 Honors — Best Final Degree ProjectExchange Program
Arizona State University
2019 – 2020Mechatronics, Robotics & Automation Engineering — Tempe, AZ, USA
Publications & Awards
A Data-Centric Approach for Real-Time Underwater Debris Detection
An Experimental Study on Marine Debris Location and Recognition using Object Detection
Read PaperThe CleanSea Set: A Benchmark Corpus for Underwater Debris Detection and Recognition
Read PaperBest Paper Award
IbPRIA 2022
AI Hackathon Winner
Best Solution — Ferrovial & Microsoft
PhD Research Podcast
Certifications
Build Next-Gen Agents with Vision Language Models
NVIDIA — 2025
Navigating NIM Agent Workflows for Multimodal Retrieval
NVIDIA — 2025
Building Conversational AI Applications
NVIDIA
watsonx Orchestrate Technical Sales Intermediate
IBM
Get in Touch
Let's work together
I'm always open to discussing new projects, research collaborations, or opportunities in AI and Computer Vision.